




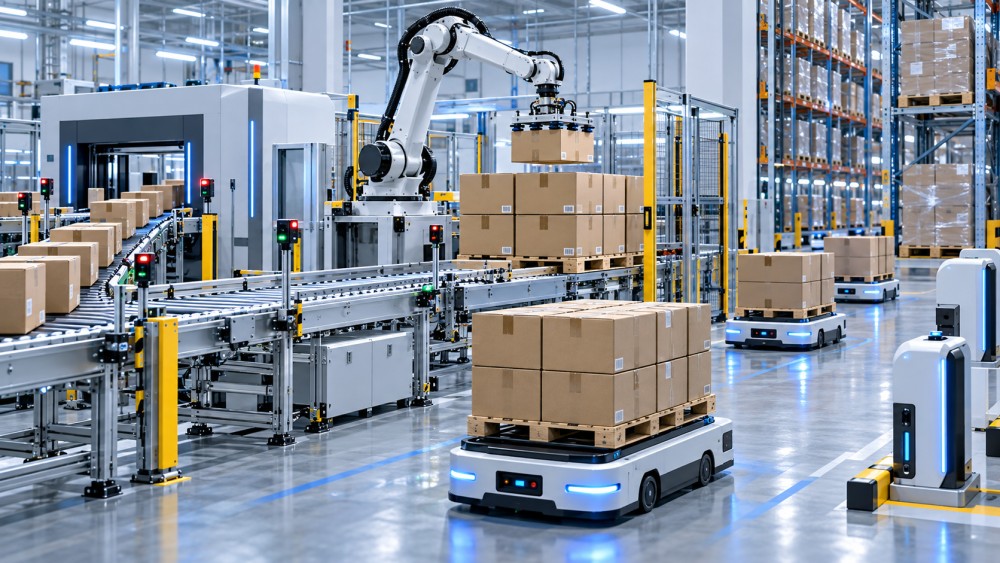
A palletizer that begins placing cartons slightly off pattern, a conveyor that hesitates at peak dispatch time, or an AMR that takes longer routes than usual can all look like isolated operating issues. In an end-line operation, they rarely stay isolated for long. A small sensor error can create rejected loads; worn conveyor components can slow sortation; a loose stretch-film carriage can reduce load containment just as outbound volume rises.
What maintenance is needed for material handling automation? The practical answer is a planned mix of routine cleaning, mechanical inspection, lubrication where specified, sensor and safety-device verification, calibration, software housekeeping, and condition monitoring. The exact balance differs between conveyors, robotic palletizers, wrappers, strapping equipment, and AGV or AMR fleets. The maintenance goal is not merely to keep a machine running; it is to preserve safe, repeatable movement, positioning, identification, and load quality.
Maintenance should follow the way equipment fails
Not every asset needs the same service interval or the same type of attention. A conventional conveyor system is dominated by moving mechanical parts. A robotic cell depends heavily on alignment, end-effector condition, guarding, and motion accuracy. Mobile robots introduce batteries, wheels, navigation sensors, maps, wireless communication, and fleet-control logic. Treating all of them as if they need one generic monthly inspection usually leaves important risks unaddressed.
A useful distinction is between operator care, scheduled preventive maintenance, and condition-based intervention. Operator care covers visible issues discovered during normal use: debris, damaged cartons caught in rollers, abnormal noise, loose film, unreadable labels, or an obstructed safety scanner. Scheduled work covers items that should be inspected or replaced based on duty cycle, manufacturer guidance, and operating conditions. Condition-based work responds to trends such as rising motor current, repeated missed scans, declining battery performance, increasing vibration, or a gradual loss of positioning repeatability.
The right program uses all three. Relying only on breakdown repairs increases disruption. Relying only on calendar-based tasks can lead teams to replace parts that are still healthy while missing a developing software, sensor, or contamination problem.
Where the maintenance workload differs by equipment type
Cleaning is a functional task, not cosmetic work
Dust, stretch-film fragments, label backing, corrugated debris, grease, and product residue interfere with more than appearance. They can block photo-eyes, foul scanner windows, reduce vacuum-gripper performance, create slip hazards, and collect around moving parts. In facilities handling powders, bags, wood products, or high volumes of corrugated cases, contamination may be the main driver of inspection frequency.
Cleaning procedures should identify what can be cleaned by operators during normal changeovers and what requires lockout and access by trained maintenance personnel. The distinction matters. A photo-eye lens may be safely wiped according to site procedure, while reaching into a conveyor transfer point or robot cell without proper isolation is not acceptable.
For mobile robots, clean optical windows, LiDAR covers, depth cameras, reflectors where used, and charging contacts with approved materials. Avoid treating navigation sensors like ordinary machine housings: abrasive cloths, unsuitable solvents, or compressed air directed into sensitive areas can create a new fault while removing the old one. After cleaning, verify that the device is reading correctly rather than assuming a clean surface means a healthy sensor.
Mechanical inspections protect throughput before parts fail
Conveyor maintenance often starts with simple observations. Listen for bearing noise, watch belt tracking, check for roller drag, inspect transfer zones, and look for loose fasteners or damaged guards. A belt that is gradually walking toward one side may indicate misalignment, uneven loading, contamination on pulleys, worn components, or incorrect tension. Adjusting the belt without finding the source can make the problem return.
High-speed sortation requires extra attention to sensors, divert actuators, carrier surfaces, and accumulation zones. A system can still run while developing a growing rate of missed reads or late diverts. Review exception patterns alongside physical inspections. Repeated faults concentrated at one induction point, scanner tunnel, or chute often provide a more useful maintenance clue than a general alarm history.
Robotic palletizing cells need checks that link machine condition to load quality. Inspect gripper pads, vacuum cups, hoses, clamps, mechanical fingers, and tool fasteners. A small air leak or worn gripping surface may not stop the robot immediately, but it can reduce pick reliability for certain carton finishes or bag materials. Confirm that product guides, infeed stops, pallet dispensers, and slip-sheet mechanisms are aligned. Pallet instability is not always caused by the robot’s programmed pattern; inaccurate incoming case presentation can be the underlying issue.
Lubricate only where the equipment design calls for it
Lubrication is frequently misunderstood as a universal cure for noise or friction. Many automated systems use sealed bearings, maintenance-light gearboxes, or components that must remain dry. Adding the wrong lubricant, applying too much, or allowing lubricant to reach belts, film-contact surfaces, sensors, or packaging can cause damage and contamination.
Use the manufacturer-specified lubricant, quantity, and interval. Record the task, especially on chain drives, gear assemblies, linear guides, and other components with defined service points. If a component needs lubrication far more often than expected, investigate for misalignment, overload, seal failure, washdown exposure, or a deteriorating part instead of simply increasing the grease schedule.
Sensors, calibration, and safety devices deserve separate attention
Automation depends on accurate inputs. Photo-eyes determine whether a carton has arrived. Barcode readers route parcels. Load cells confirm weight. Vision systems identify orientation. Safety scanners and interlocked gates determine whether motion is permitted. These devices may appear intact while performing poorly because of contamination, vibration, shifted mounting, poor lighting, damaged cabling, or configuration changes.
Calibration should be risk-based. A system used for simple presence detection may require functional verification and alignment checks. A robot using vision-guided picking, a wrapper using height sensing, or a sorter relying on dimensional and weight data may need more formal accuracy checks against known references. The process should confirm both the device reading and the downstream response. A scale that reads correctly but passes incorrect data to the control system still creates an operational problem.
Safety circuits should never be treated as a nuisance source of stops. Test emergency stops, interlocks, light curtains, safety mats, scanner protective fields, audible or visual warnings, and restart behavior under documented procedures. A repeated safety trip warrants investigation. Bypassing, masking, or casually repositioning a safety device may restore output temporarily while creating unacceptable risk.
Software maintenance is part of physical equipment reliability
Material handling automation is controlled by programmable logic controllers, robot controllers, drives, warehouse interfaces, fleet managers, vision configurations, and often wireless infrastructure. Mechanical service alone cannot prevent failures caused by corrupted settings, outdated maps, poorly managed user access, or an untested software change.
Maintain secure backups of controller programs, robot recipes, parameter sets, navigation maps, and configuration files. Backups should be versioned and validated so that restoration is possible after a hardware replacement or failed update. Keep a record of changes to motion settings, pallet patterns, scan rules, network settings, and safety parameters. When output behavior changes after a modification, this record is often the fastest route to diagnosis.
Updates need control rather than automatic deployment across production equipment. Review compatibility with connected devices, schedule a maintenance window, preserve a rollback option, and verify the equipment’s normal operating sequence after the change. For AGV and AMR fleets, also confirm map integrity, traffic rules, charging logic, and communication quality. A software update that improves one function but disrupts fleet coordination is not a successful maintenance action.
Battery and charging care for mobile fleets
AGV and AMR availability is shaped by battery condition as much as route planning. Inspect charging contacts for contamination, wear, heat damage, and consistent engagement. Review charging exceptions and repeated low-state-of-charge events. A robot that frequently leaves service for charging may be revealing battery aging, poor opportunity-charging logic, a charger issue, excessive route distance, wheel drag, or a task-assignment problem.
Battery maintenance must follow the battery chemistry and supplier instructions. Do not apply lead-acid habits to lithium-based systems, and do not assume every pack should be deeply discharged before charging. Watch for physical damage, swelling, abnormal heat, connector condition, and alarm messages. Battery replacement decisions should consider operating runtime, charging behavior, mission demand, and safety condition rather than age alone.
Use operating data to decide what requires attention first
Preventive schedules are essential, but operational data helps maintenance teams focus effort. Useful signals include motor current, drive faults, cycle time, stop frequency, scanner read rate, robot recovery events, film-break frequency, battery state trends, charging failures, and repeated location errors. A single alarm may be incidental. A gradual trend across shifts is often more significant.
For example, a stretch wrapper using more film than expected may have an incorrect setting, but it may also have slipping pre-stretch rollers, worn film carriage components, inconsistent film supply, or a sensing issue that changes overlap. The maintenance response should compare the machine’s physical condition, setup parameters, and product mix before replacing parts.
Likewise, an AMR that appears slow may not have a drive fault. Check whether the fleet manager is assigning longer paths, whether a safety scanner is detecting frequent obstructions, whether Wi-Fi coverage is unstable, or whether traffic-control rules are creating congestion. Maintenance and operations need a shared view of these signals because the symptom may cross mechanical, electrical, software, and workflow boundaries.
A practical service rhythm without over-servicing
Daily and shift-level checks should be short and observable: remove debris, inspect guards, confirm sensors are unobstructed, look for leaks or damaged cables, listen for unusual noise, and report faults that recur. Operators should not be expected to diagnose control logic, but clear reporting of where and when a problem occurs makes later work more effective.
Weekly or periodic tasks can go deeper into belt condition, chain tension, roller movement, gripper wear, air quality, film paths, strapping components, wheel condition, charging contacts, and accessible fasteners. Longer-interval service may include calibration, detailed safety validation, gearbox or drive checks, battery health assessment, software backup verification, and replacement of wear items identified in the equipment documentation.
The schedule should be adjusted after observing actual duty cycles. Equipment handling abrasive loads, running multiple shifts, operating in dusty areas, or experiencing frequent washdown conditions will not age like equipment used intermittently in a controlled environment. Conversely, a low-use machine may suffer from neglected batteries, seized components, or degraded connections even when its cycle count is low.
When a recurring fault needs a deeper review
Escalate beyond routine maintenance when the same failure returns after cleaning, adjustment, or replacement; when a safety function behaves inconsistently; when a robot drops or misplaces loads; when a conveyor repeatedly jams at the same transfer; or when mobile robots show unpredictable navigation or charging behavior. Repeated resets hide the evidence needed to solve the real problem.
Capture the fault code, time, operating mode, product or load involved, recent changes, and the physical condition observed. Then separate symptoms from causes. A missed carton may be caused by a photo-eye, but also by timing, belt slip, carton geometry, reflective packaging, or an upstream release issue. That disciplined approach keeps material handling automation reliable without turning every minor interruption into an unnecessary major service event.
Related News
- What drives automated pallet handling price in a warehouse project?Oct 08, 2026Automated pallet handling price depends on throughput, load variation, integration, safety, and site conditions. Explore the key cost drivers for smarter warehouse investment.
- When does warehouse automation ROI justify an autonomous forklift fleetOct 07, 2026Warehouse automation ROI: discover when an autonomous forklift fleet delivers measurable returns through repeatable flows, lower costs, safer handling, and stronger throughput.
- What Maintenance Does Material Handling Automation Need?Oct 05, 2026What maintenance is needed for material handling automation? Discover practical care for conveyors, robots, AMRs, sensors, safety systems, and software to reduce downtime.
- How Accurate Is Machine Vision for Reading Pallet Labels?Oct 02, 2026How accurate is machine vision for pallet label reading? Discover how lighting, label quality, AI, and validation improve warehouse accuracy and throughput.
Related News
- 00
0000-00
Which design features make warehouse cross-belt sorters low-maintenance? - 00
0000-00
When should you choose a shoe sorter over a cross-belt sorter? - 00
0000-00
Preventing bottlenecks in conveyor-fed robotic end-of-line packaging - 00
0000-00
What CE documentation should an end-of-line automation exporter provide? - 00
0000-00
What throughput should a high-speed sorting systems factory guarantee?
Autonomous Intralogistics Strategist
Weekly Insights
Stay ahead with our curated technology reports delivered every Monday.